The DVIDIA manifesto · Our north star
More time
to be human.
A future where more work is a choice.
And more of your time is yours.

The future we’re working toward
What would you do
with that time?
Grow something. Make music. Learn a craft. Spend an unhurried afternoon with someone you love.
Our ambition is shared abundance: life’s essentials within reach, more useful work that machines can help with, and more freedom to decide how we live.
We want to help people move from work they have to do toward things they choose to do. The things we love doing can stay ours.
An open question. A shared undertaking.
What can’t we
teach a machine?
Useful routines are a place to begin. Beyond them is a world of variation, judgment, taste and care. Let’s show what we know—and discover what can be shared.
A thought experiment. Not a measured share of work or robot capability.
A useful place to start.
Fold a towel. Sort a part. Repeat a careful routine. The work matters, even when the desired result stays the same.
How far could we get, together?
How quickly could many people explore what one person never could? Share a task. Add another way of doing it. Test what a machine can learn. Some things may remain beyond it; others may be ours to keep by choice. There is no measured percentage or finish date. The open question is how much we can discover together.
Many kinds of useful knowledge
From useful routines
to a human signature.
Share the routines that free our time. Preserve the technique, judgment and taste that make work human. Every kind of knowledge belongs here—and every contributor deserves credit.
Crowdsourcing the way forward
Many people.
Many ways of knowing.
A carpenter’s judgment. A grower’s timing. The small adjustment that makes a repair work. By bringing our experience together, we aim to shorten the path from a demonstration to a tested, reusable skill. Many people can explore different tasks in parallel, share what holds up, and make the next experiment better.
The path we’re building
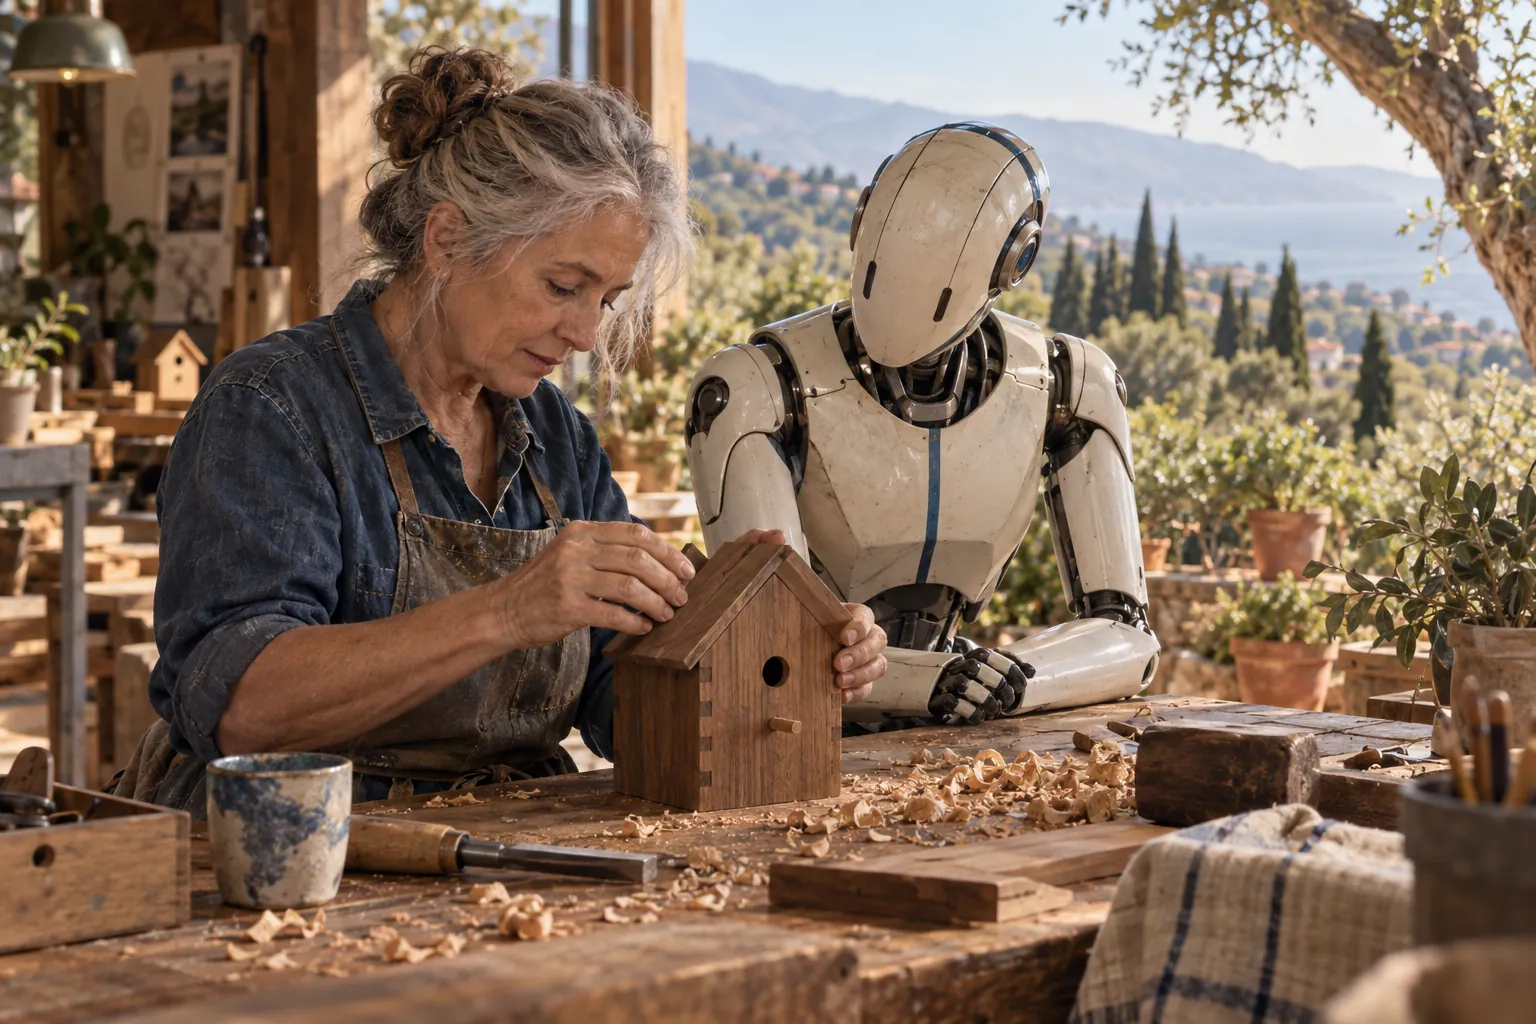
Every useful skill starts with someone.
The details in an everyday repair can become a useful demonstration—shared by choice, with the maker’s credit intact.
Demonstrations are the beginning. Review, training, suitable hardware and real-world testing still have to turn them into useful capabilities. Open results let the next person build on what the last person learned.
Progress people can share in
The future should include
the people who teach it.
Technology alone cannot guarantee that everyone benefits. Access, ownership and how value is shared are choices we make together. They belong at the heart of the work.
Your choice.
You decide what to contribute. Permission and the rights you hold stay visible.
Your credit.
Knowledge has people behind it. Credit should travel with every contribution.
A shared upside.
Open releases stay accessible. Future paid services should support contributors through agreed terms and revenue actually collected.
From the vision to the work
One house. Two connected paths.
DVIDIA brings human demonstrations, datasets and the path to tested robot skills together. Our open-weights desk, OpenWeights Terminal, connects model research with machines that run inference. Open knowledge, and useful services around it.
The thinking behind the visionRead our practical foundations
01 / The conviction
No company should own humanity’s skill library.
Folding, fixing, growing, assembling, explaining: useful knowledge comes from people doing the work. Turning that knowledge into AI should not require handing a private company exclusive control over what everyone else can learn.
Our thesis is that edge inference and robotics will make intelligence part of everyday infrastructure. More of it will run close to the person, on a local machine, or inside a physical system. The skills behind that infrastructure should be inspectable, adaptable and available beyond any one platform.
Teach it once. Let more people build on it.
DVIDIA’s commitment is to open skill releases, portable artifacts and visible credit. Contributors keep the rights they hold. A workspace helps organize the work; it does not grant ownership of an everyday action. We will not make exclusive corporate ownership of shared skillsets our business model.
02 / The opportunity
The scale is real.
Access is the unfinished work.
Robotics already has a substantial installed base. Open weights already serve real inference demand. The opportunity is to make useful capabilities easier to share, adapt and run across people, software and machines.
Industrial robots in operation
Estimated worldwide stock in 2024. IFR also reports 542,076 installations that year.
IFR · World Robotics 2025Industrial robot installations
Global market value reported by IFR on 8 January 2026; the release does not specify its measurement year.
IFR · January 2026Open-weight token share
On OpenRouter near the end of its 2025 study. A platform observation, not global or private inference share.
OpenRouter · December 2025These figures measure different things and cannot be added into a total market. We have no verified estimate of the worldwide private inference market or DVIDIA’s addressable revenue. Our market starts with specific tasks people can reproduce and services they choose to pay for.
03 / The raw material
Start with someone doing the work.
The supply comes from demonstrations people choose to contribute, consented robot teleoperation, openly licensed research, and clearly labeled simulation or scripted rollouts. Preserve who made each contribution, how it was collected and what its license permits.
Make hard-earned know-how easier to learn.
Some of the most useful skills are hard to capture because the important decisions live in experience. We want to make room for people who can demonstrate a craft, explain their judgment and recognize when a situation calls for a different approach.
Roofing
The experienced judgment behind assessing a roof and adapting to different materials, buildings and conditions.
Wall insulation
Understanding how materials and existing construction shape the work, and recognizing the details that deserve closer attention.
Carpentry
Judging fit, grain and finish, and adapting when real materials differ from the plan.
Teaching, filming, reviewing and improving this work all create value. Credit should follow each contribution into the release. Future paid downloads, installation services and use should fund compensation under agreed terms, from revenue actually collected. The underlying open releases stay accessible; a useful paid package should support the people who made it.
These are areas we want to develop with practitioners. These skill releases are not available today.
BridgeData V2
60,096 robot trajectories: 50,365 teleoperated demonstrations and 9,731 scripted rollouts.
Open dataset / CC BY 4.0DROID
76,000 successful demonstrations, about 350 hours, collected across hundreds of real scenes.
These are foundations to learn from, with specific robots, tasks and licenses. Publicly visible footage is not automatically reusable training data. A person’s video can explain a task, but it cannot supply robot actions or sensor readings that were never recorded. Missing information stays missing.
04 / From data to skill
A useful skill has to survive contact with the world.
Distillation means preserving the parts that make a task work: the goal, conditions, steps, actions, feedback and recovery from mistakes. A collection of clips is a starting point. An executable, evaluated release is the result we are working toward.
- 01
Record with provenance
Keep original media, the task, contributor credit and permission to use it. Sharing begins with an explicit choice.
- 02
Structure the evidence
Curate episodes and annotations. Preserve real sensor and action data. Robot datasets must pass a LeRobot v3 load-and-replay check.
- 03
Build and test the skill
Produce an agent workflow, script or trained robot policy. State the supported model, hardware and environment; measure outcomes and failures.
- 04
Release something reproducible
Publish the version, source, component licenses, data references, setup instructions and evaluations so others can inspect, improve and run it.
05 / Private inference
Your model.
Your machine. Your rules.
Open weights let people choose where inference runs. A workshop can use a local machine. A team can operate a private server. A community can offer compatible compute and compete on price, performance and reliability.
By liberated, we mean the freedom to inspect, adapt and operate a model on your own terms—including deployments without a hosting provider imposing additional content filters. People should be able to choose unfiltered models and control their own runtime policies. Downloadable weights still carry their licenses and behaviors learned during training; the word “open” alone does not remove them.
Local inference already makes private operation possible. Ollama documents local-only mode and says it does not see prompts when models run locally. Remote tools and hosted services have their own data paths, which should be visible to the person using them.
Read Ollama’s local inference documentationOpenWeights Terminal is DVIDIA’s open-weights desk. Its direction is a competitive inference market built around portable models, clear terms and verifiable service. Keep private work private. Make switching providers possible. Drive the cost of useful intelligence down through shared work and competition.
06 / An open economy
Make access cheap.
Make contribution worthwhile.
The ambition is broad access at the lowest practical cost. Useful open releases should remain available to study, adapt and run. Original licenses and attribution travel with them, and anyone should be able to build compatible tools around them.
Premium skill spaces will be paid places to develop and maintain a skill together. Creators will be able to set prices for packaged downloads and useful services, while the underlying open-source releases remain accessible. People can pay for a maintained package, an adaptation, evaluation, support or delivered compute. Participation should not require surrendering the skill to a platform.
Contributors should share in the value of work that earns revenue. That requires recorded contributions, agreed terms and a clear calculation based on collected sales. A free download does not create an earnings balance. A paid workspace does not buy exclusive rights to an everyday human skill.
The founder skillspace is our proposed starting point: a paid workspace with a branded first-person recording necklace, where someone takes responsibility for a useful task, recruits contributors and helps improve the release. We are exploring an 80% founder share of a defined revenue pool. Pricing, hardware fulfillment and the complete contributor agreement must be established before that proposal becomes an offer.
Inference operators follow a separate path: open-source management software, verified endpoints, measured usage tied to an authenticated account and settlement address, and payment from collected customer revenue. Any network-token rewards need separate, published rules. A connected machine or a token counter is not an earnings balance.